Build diary
Day 0 is the day we chose the robot; Day 1, the day the servos were ordered. Each entry says which print plates it's about, so you can follow a part from the first try to the one that fitted.
-
Day 9
Every PLA plate printed
Eighteen plates and about 39 hours of printing later, every PLA part of the duck exists, and face plate v1 is in with its screen and camera. Only the TPU soles and beak edges are left, and the servos are still on their way.
-
Day 8
Firmware for a face
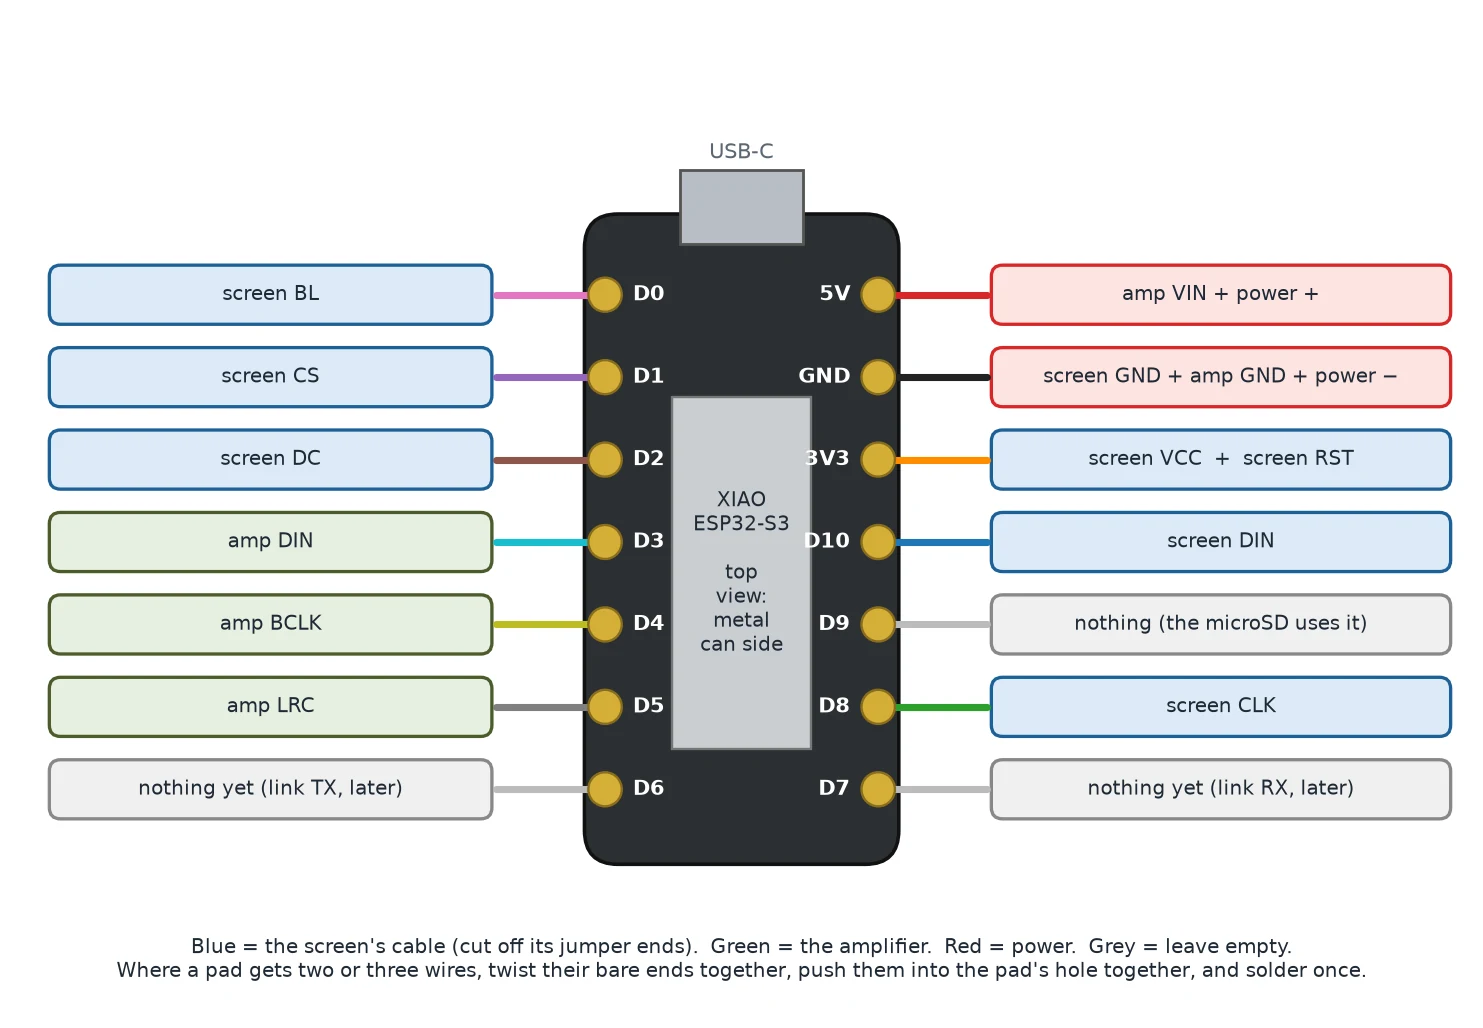
The servos aren't here, but the head doesn't need the rest of the robot to come alive. A bench stand, firmware for the eye, camera, microphone and speaker, a small servo driver, and a ten-page guide to wiring it all up.
-
Day 8
A screen for an eye, a camera for the other
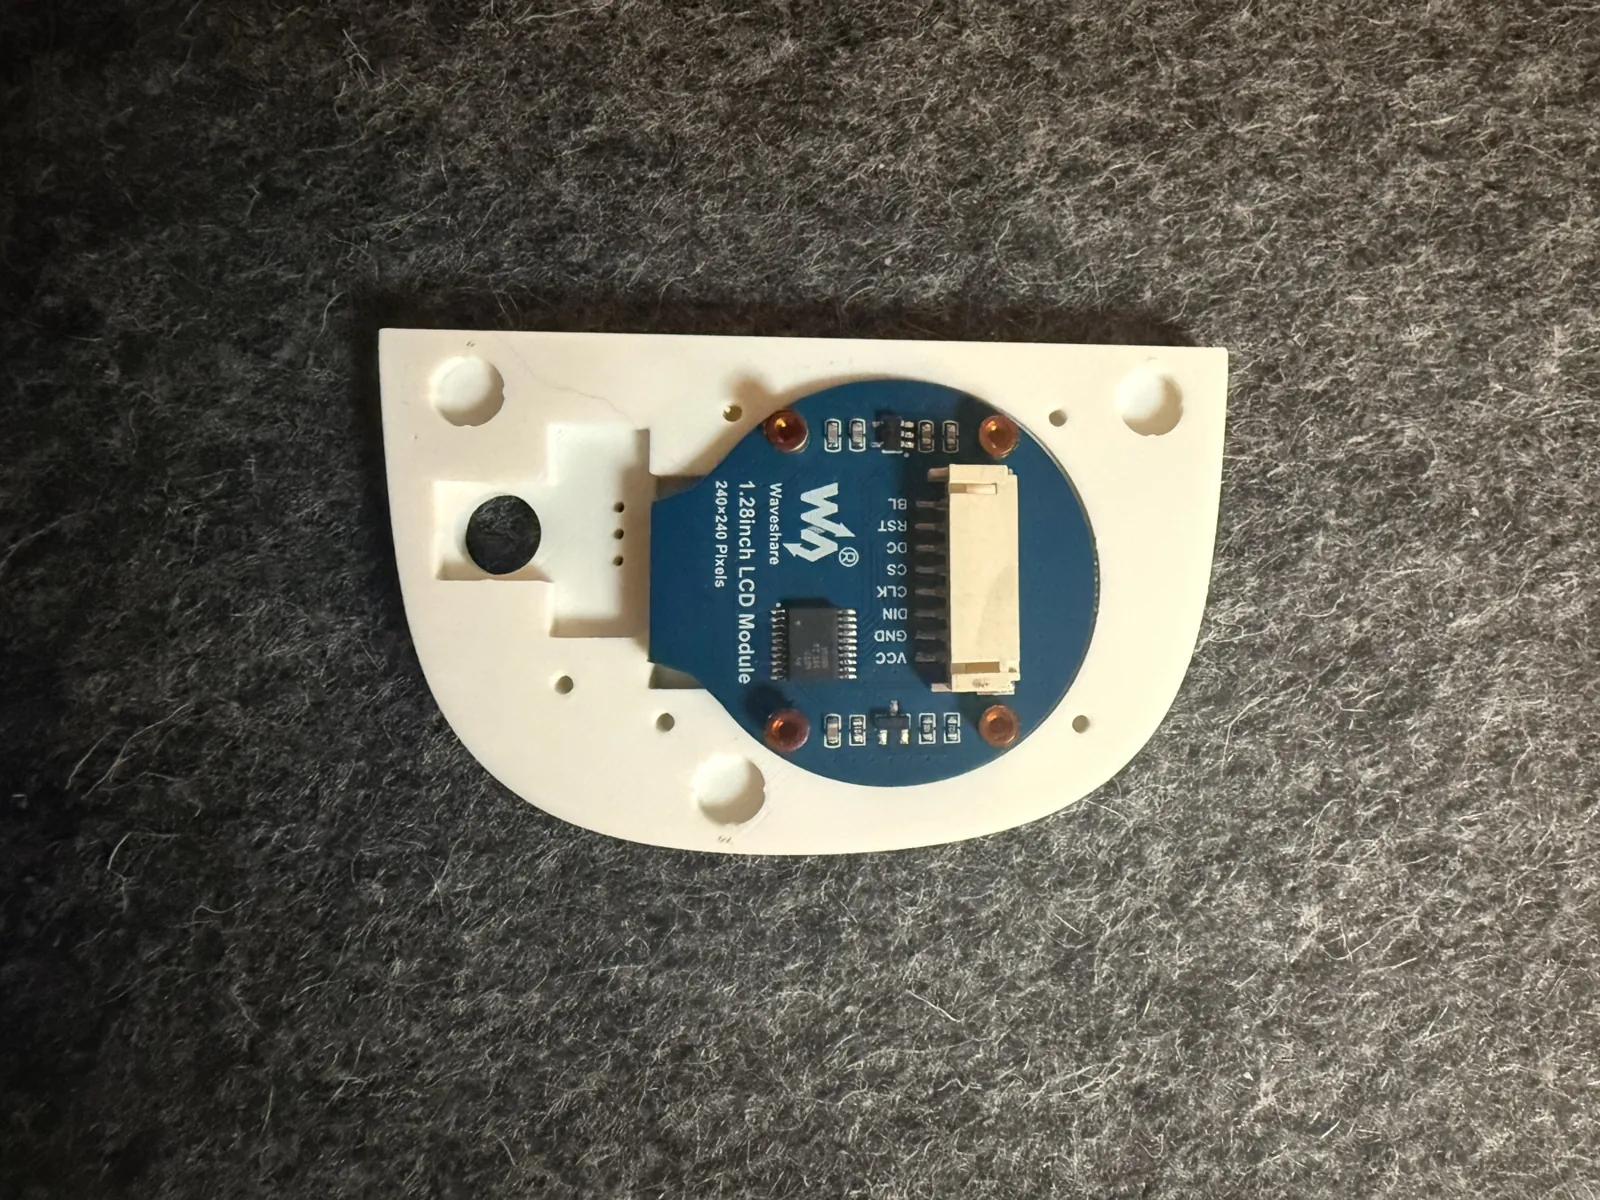
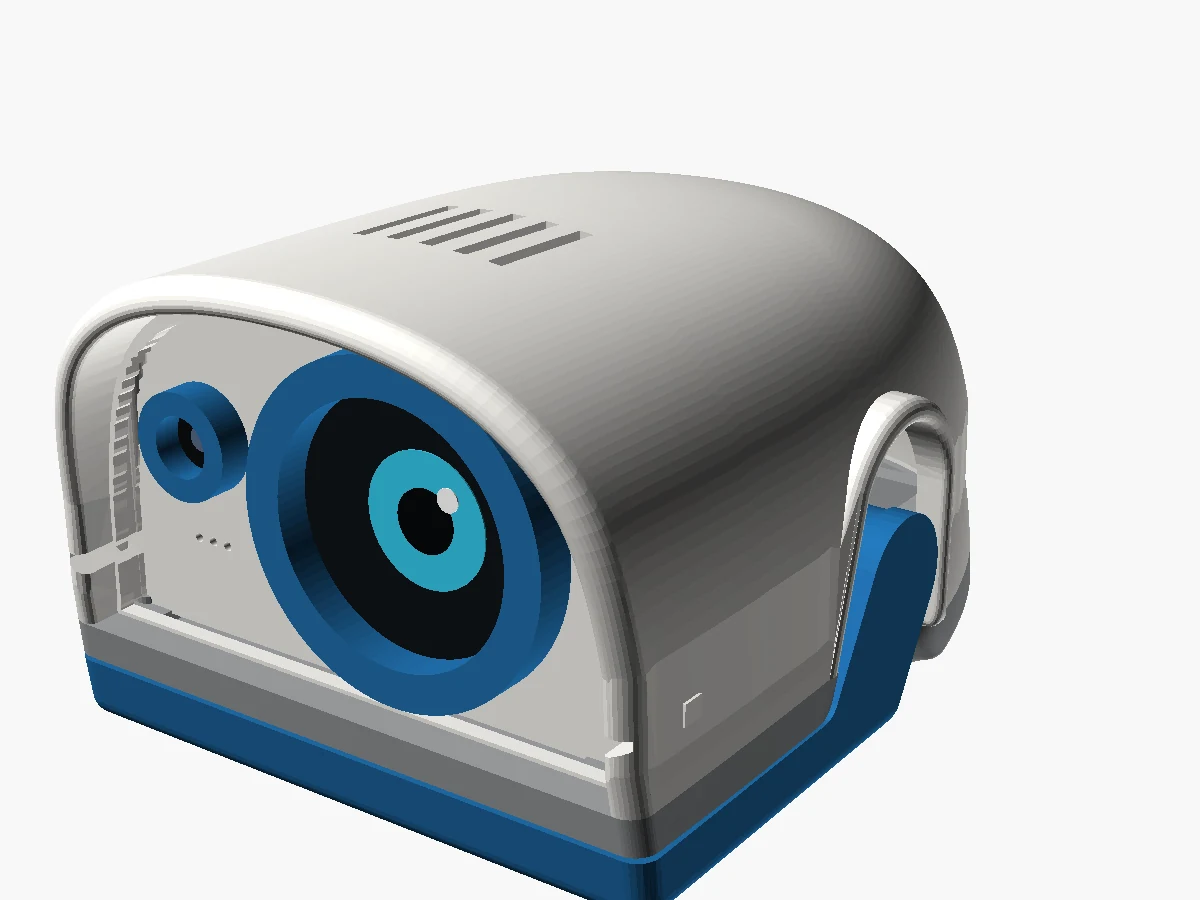
The screen and the XIAO camera board arrived, so out came the calipers. Face plate v1 holds both. Getting there took a drooping lip, a wedge-shaped tab and a camera 4 mm off.
-
Day 4
-
Day 3
Our first face went in backwards
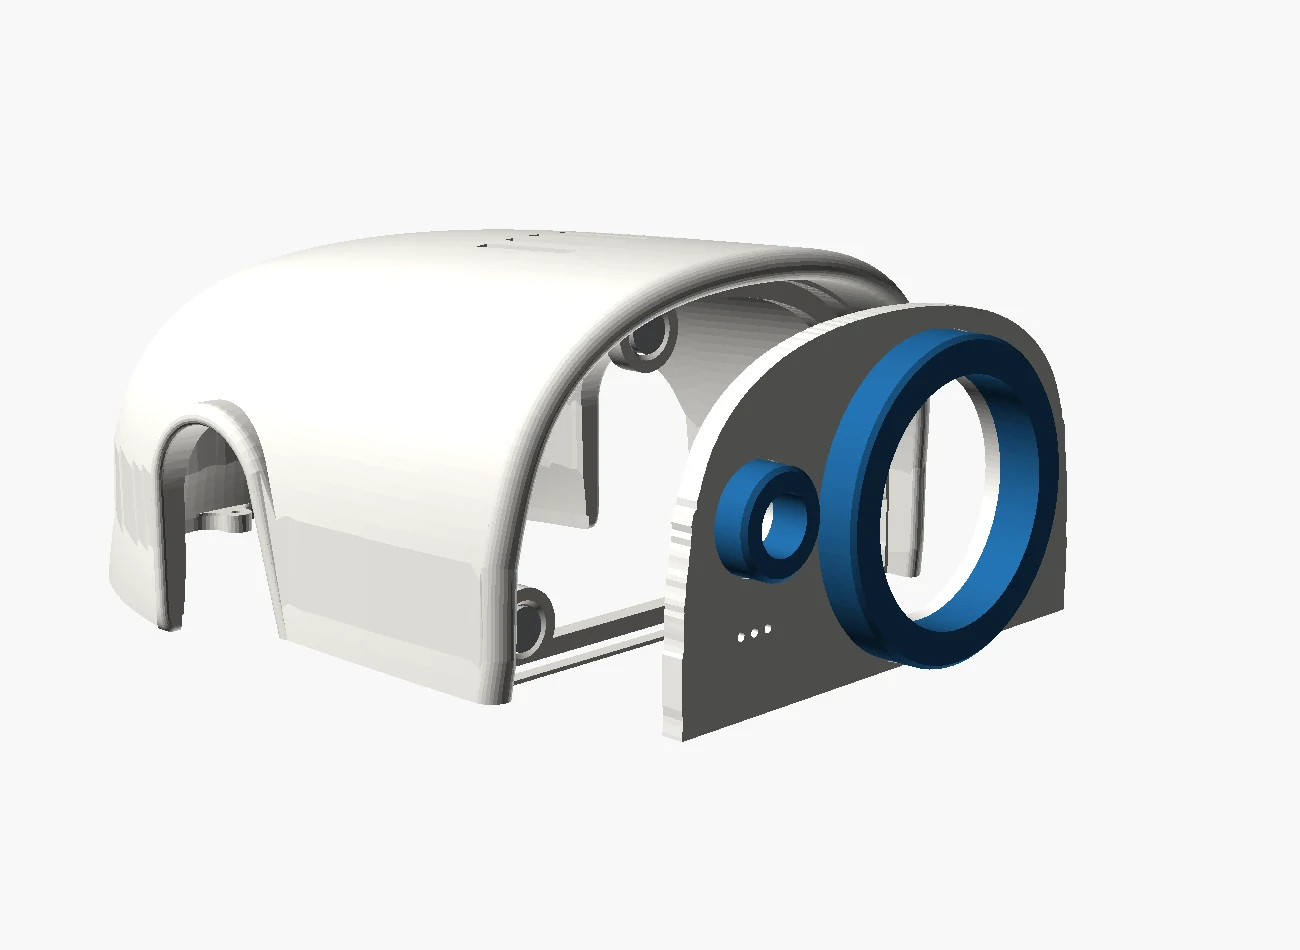
The new head: a taller hood with a face that comes off, held by three magnets. The first face printed mirrored and the magnets fell out.
-
Day 2
The leg link that wouldn't print a round hole
Three prints of one small recess, then a sweep of every part for the same kind of trouble. It found towers of support thin enough to knock over, supports welded to parts, and a prime tower bigger than the bed.
-
Day 1
-
Day 1
Sixteen servos on pre-order
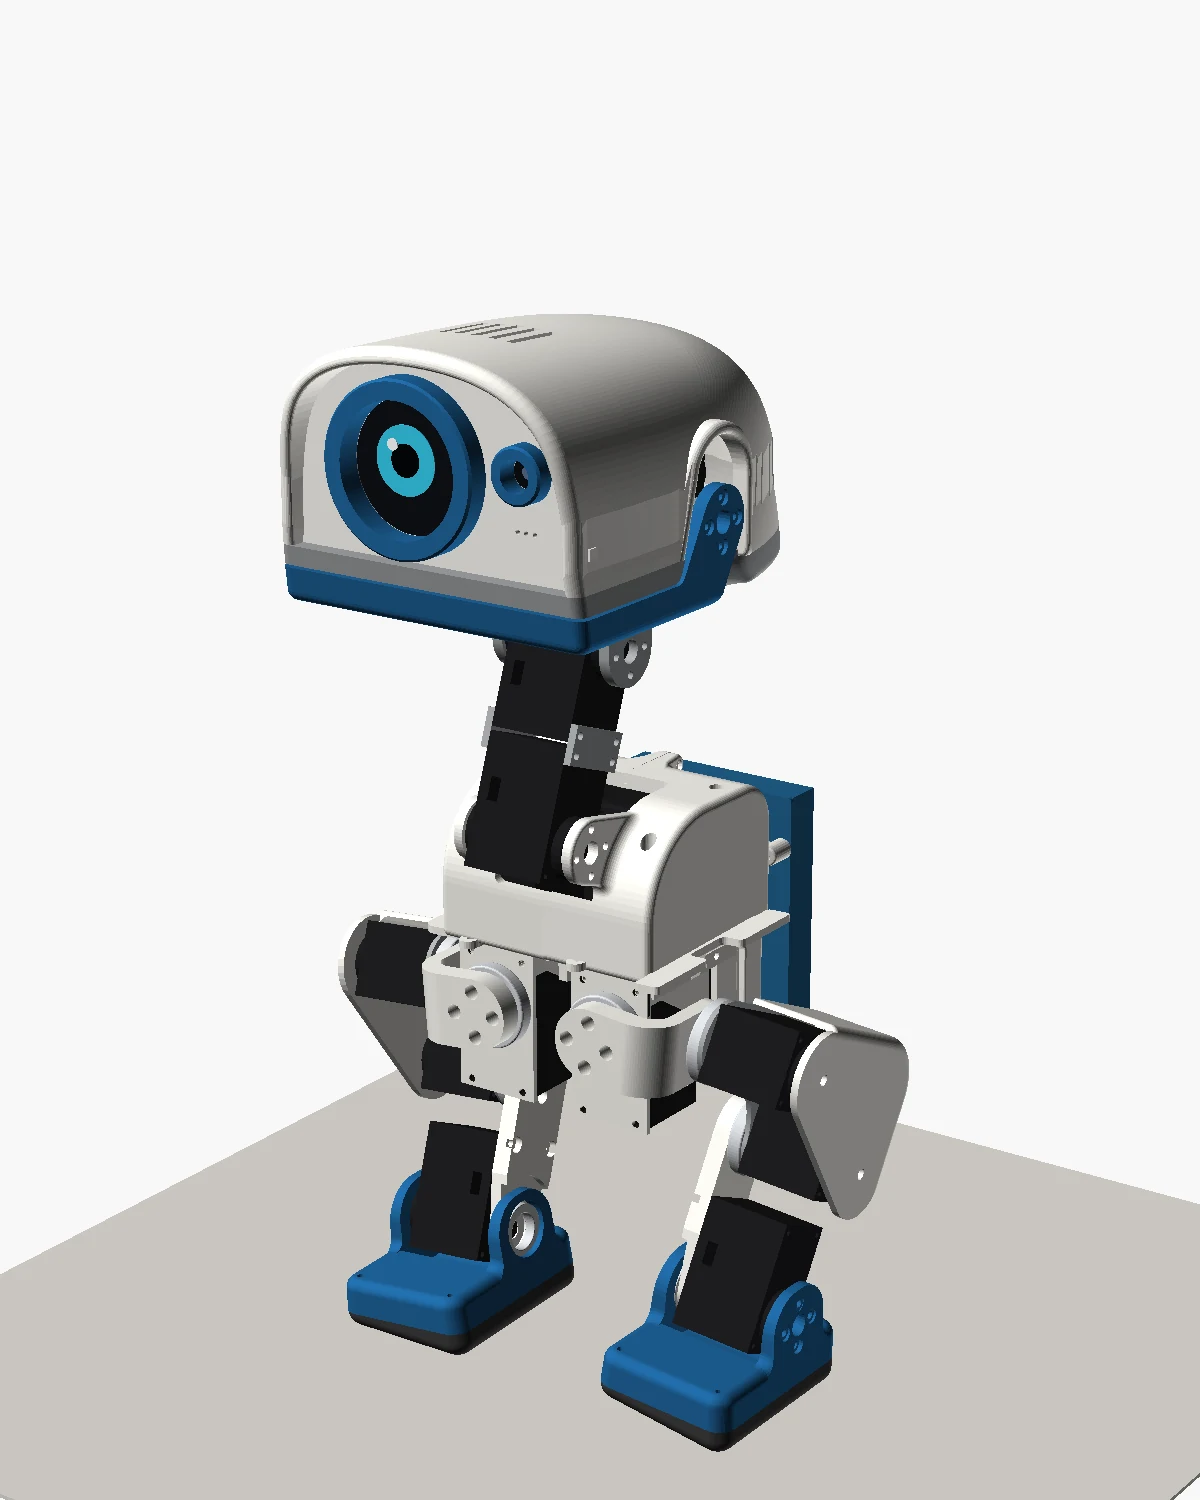
Day one: what XGO-Duck is, why we are building one, and the parts list turned into UK shops and prices. The servos alone are most of the bill.
-
Day 0
Which robot?
The plan started as a 70 cm brushless walking droid. A day of reading later it was a 25 cm printed duck. Here is what we looked at, and what each one would have cost.